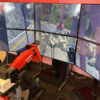
MIT engineers have designed a more intuitive way to operate excavators, replacing the traditional joysticks that can take years to master. The new controller, called the World-Space Interface, is shaped like a miniature excavator arm and bucket. Operators simply move their own arm and hand, and a digital excavator mirrors those motions on an immersive six-screen display, cutting out the mental translation joysticks require. In week-long training trials, novices using the new interface performed as well as experts from day one, while joystick-trained novices stayed behind experts throughout. The team, led by Hermano Krebs and developed with Sumitomo Heavy Industries, is now adding haptic feedback so operators can feel the weight of what they’re digging, and envisions the design used both in physical excavator cabs and remote teleoperation setups.
Related Posts
 SpaceX revealed New Breakthrough Upgrade on Raptor 3 Engine in 2026 Totally Ahead of Time
SpaceX unveils a major upgrade to its Raptor 3 engine, showcased during the Flight 11…

MadisonSeptember 16, 2026
 Start Young!
Engineering in early childhood has many benefits. It helps children develop problem-solving skills, communication capabilities, and…
MadisonMarch 20, 2025
 Just amazing! Figure unveiled new humanoid robots which can complete complex household tasks.
Just amazing! Figure unveiled new humanoid robots which can complete complex household tasks. #AI #roboticsengineering…
MadisonFebruary 28, 2025